The Ballbot
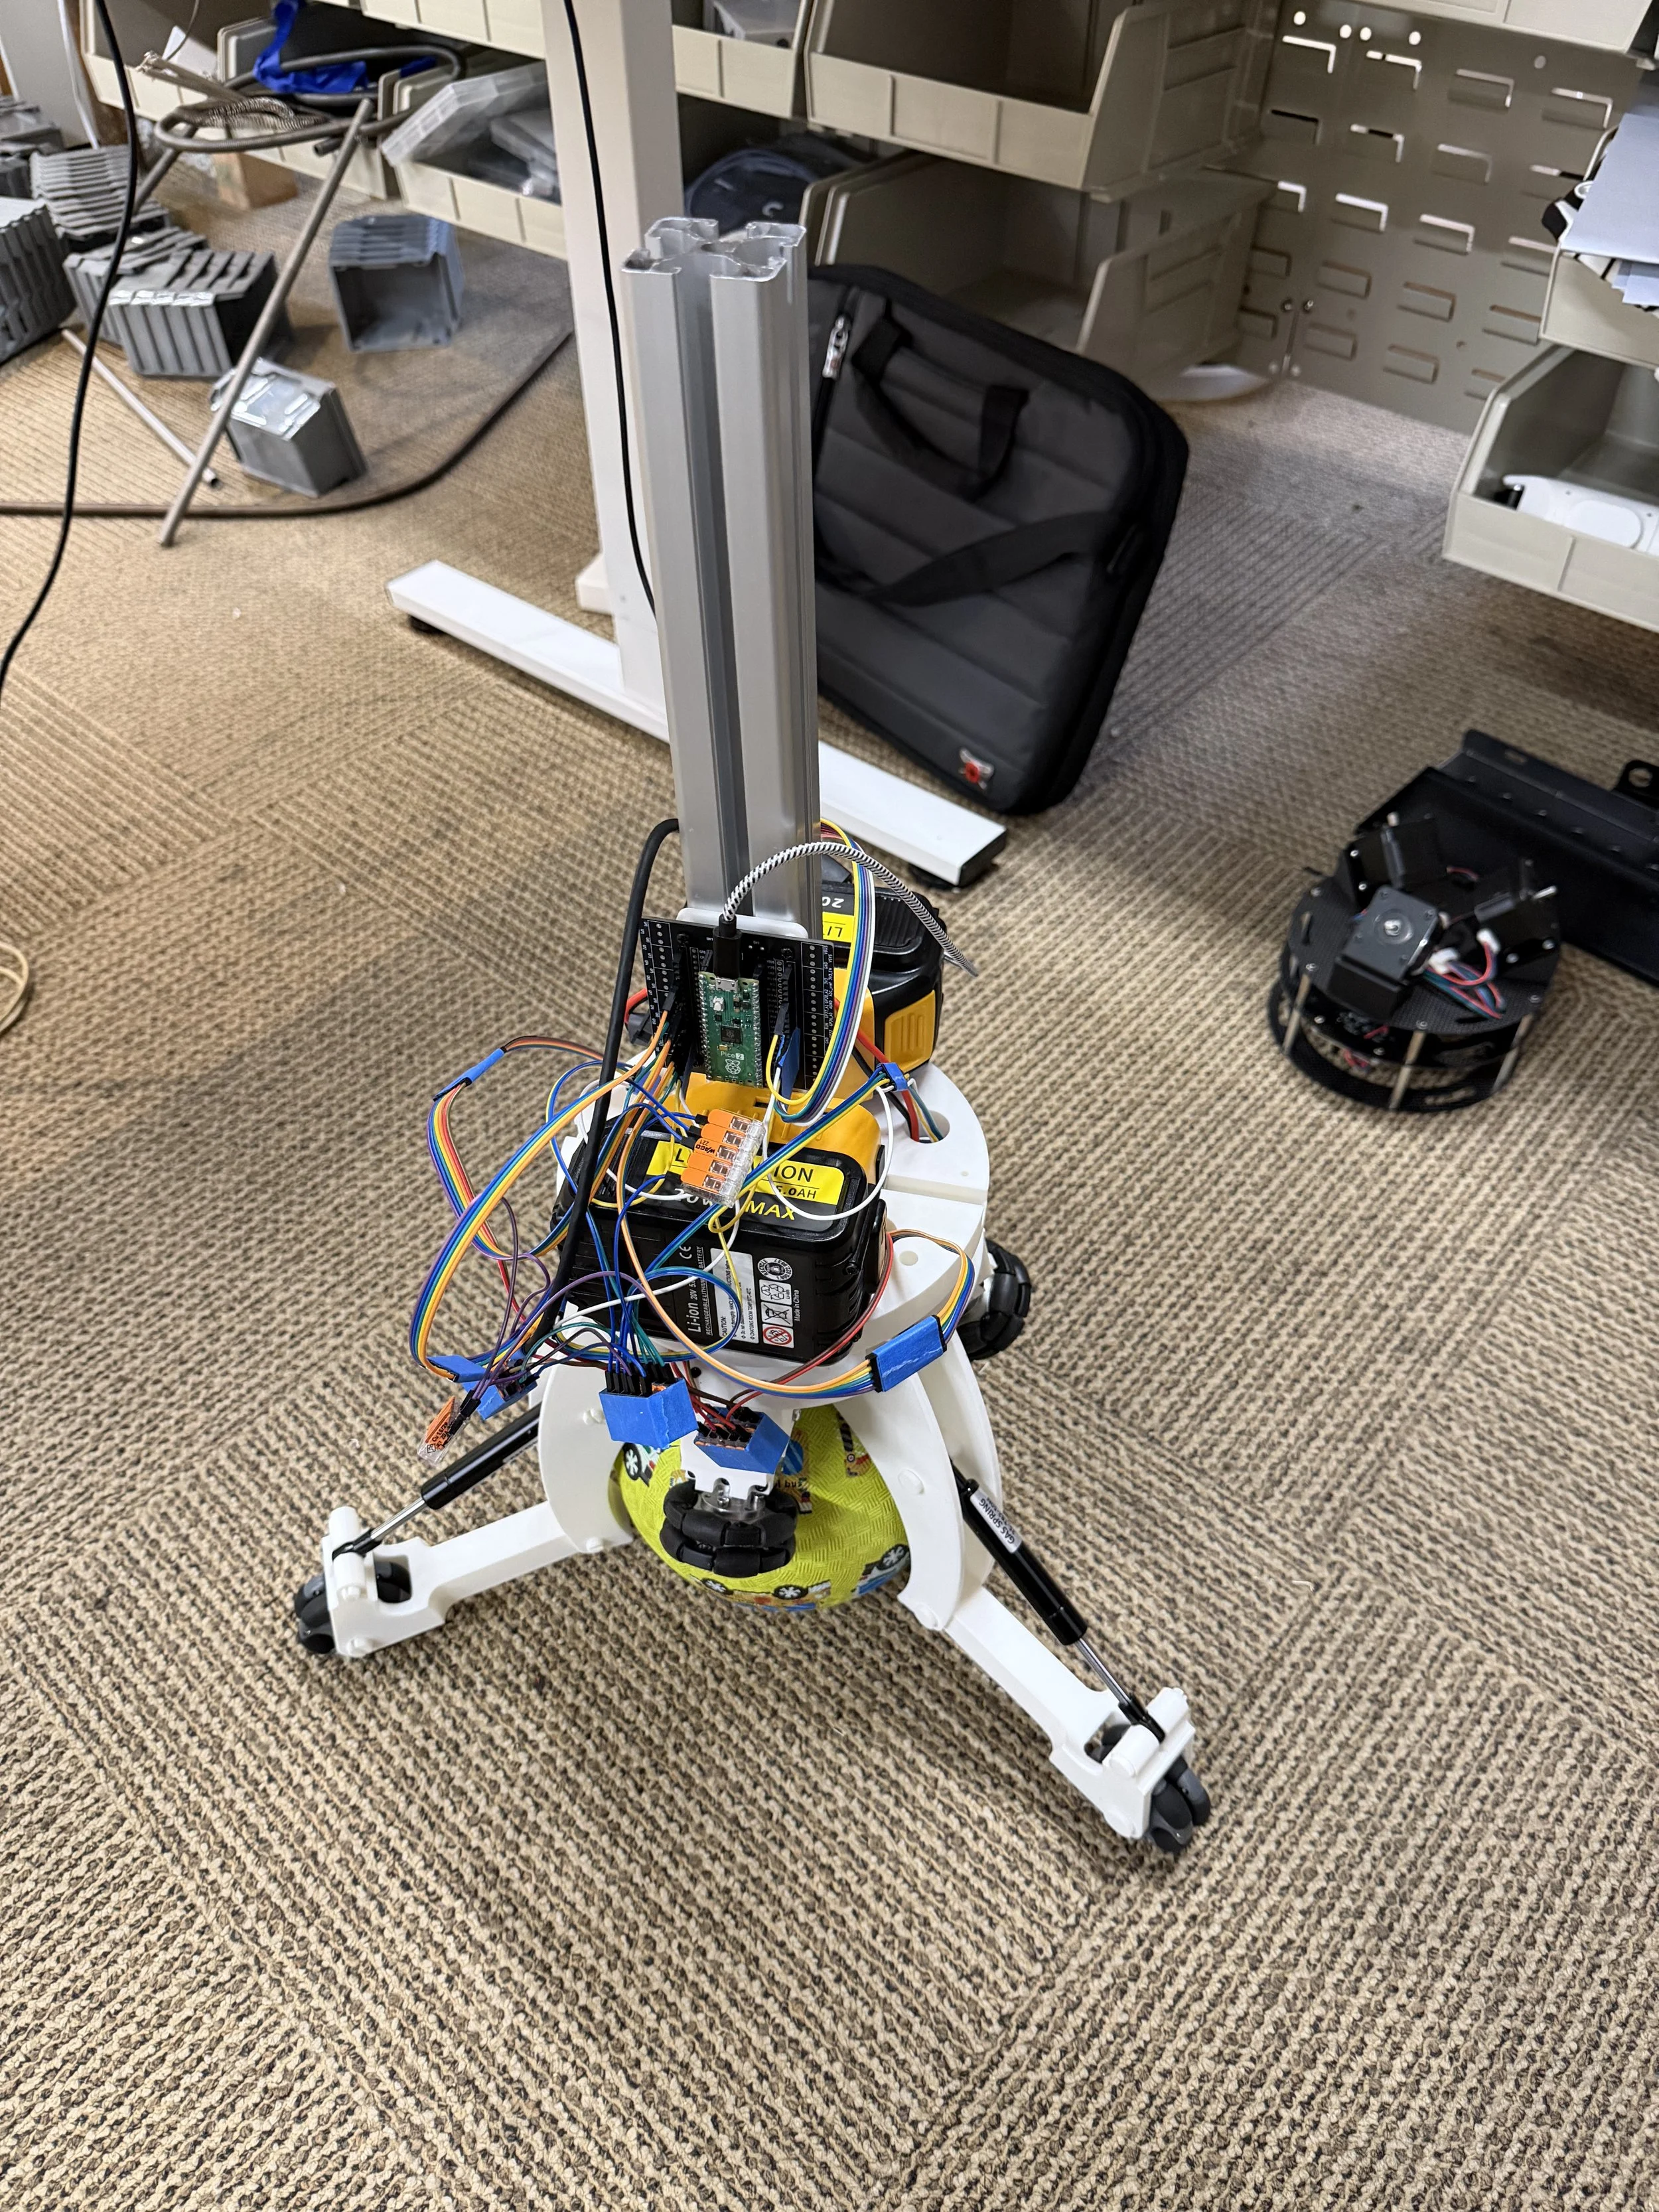
This is a robotic locomotion platform that uses 3 Omni wheels to drive a ball.
It is controlled by a Raspberry Pico 2. It uses 3 pairs of DC motor drivers and motors from Pololu. The control algorithm uses a PID balancing controller and a PI speed controller to control motor speed.
I designed the entirety of the project, including both mechanical and electrical system.
The training wheels will be removed when the robot is able to balance on its own.
Balancing kinematics
The video shows the omni wheels are driving the ball in the opposite direction of the robot’s tilt.